Project · Class 7
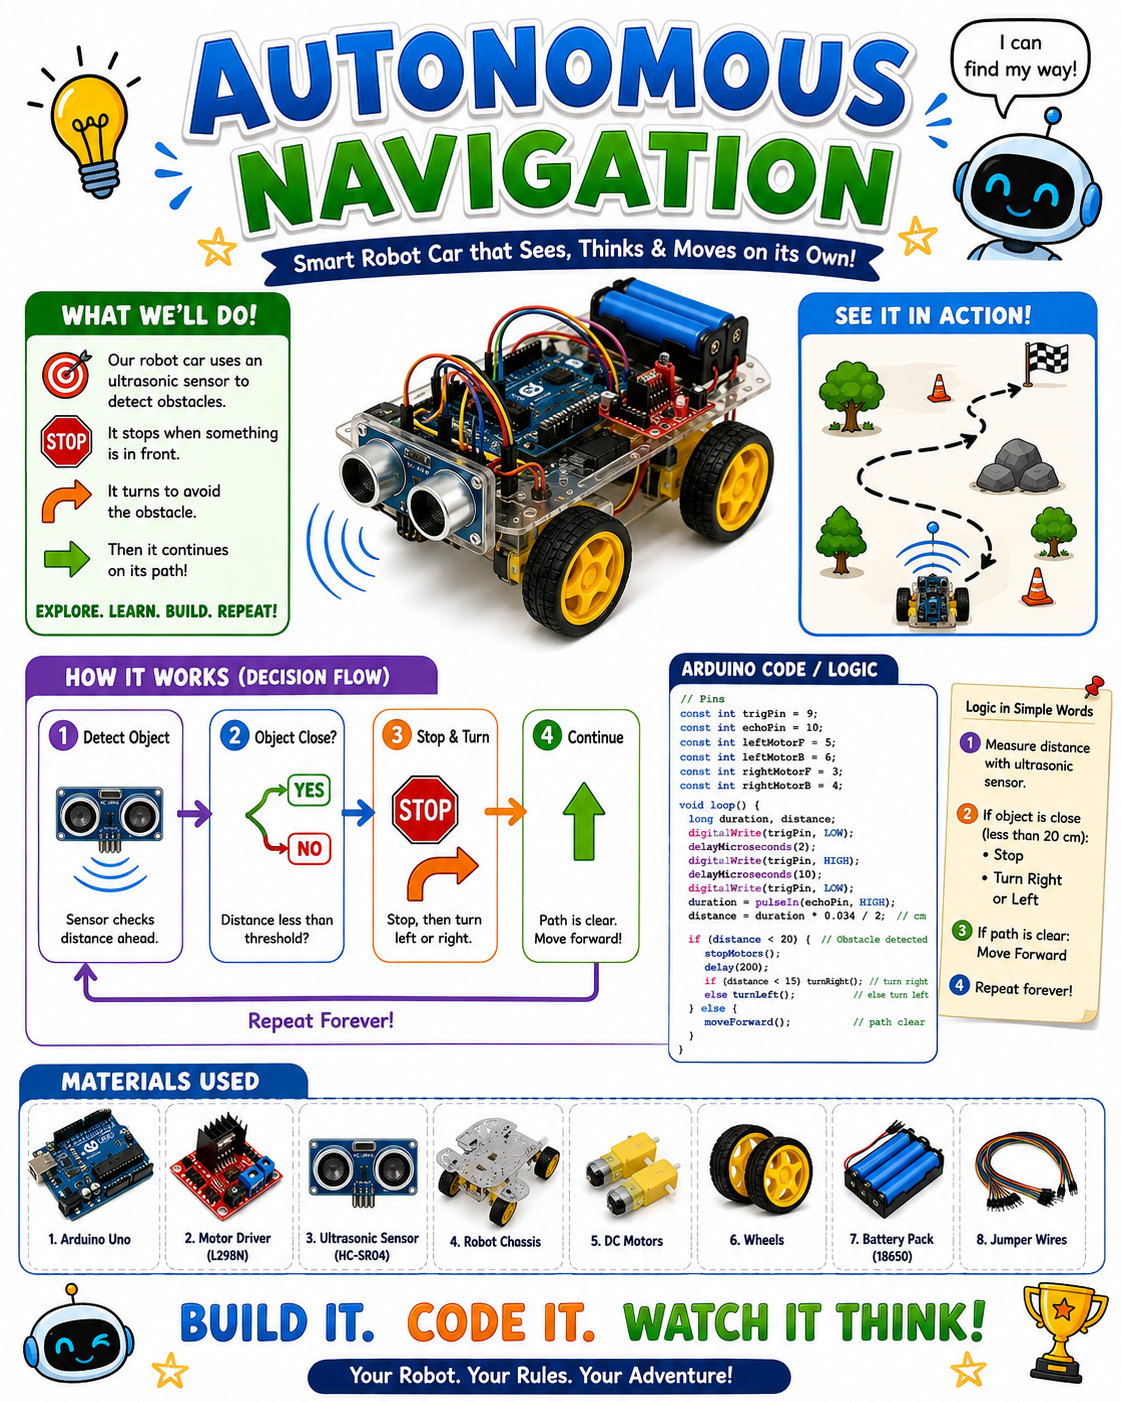
Autonomous Navigation
Program the robot to decide when to stop, turn and avoid obstacles on its own.
ArduinoSensorsMotorsLogic
Project detail
Program the robot to decide when to stop, turn and avoid obstacles on its own.
Programmed physical movement
Sensor-based input and automatic response
Hands-on electronics and coding
Real-world problem-solving
Iterative testing and improvement
Decision making1 image
My role
Designed, assembled, programmed, tested and refined the project as part of a hands-on robotics learning journey.
Next project · Class 7